





Minsu (Max) Chang, Ph.D. • Robotics Research Engineer at Samsung Electronics (SAIT)
Spatial Intelligence, Physical AI, Multi-Robot Task & Motion Planning (TAMP), and Rehabilitation Robotics


🏆 Recent News • 📝 Technical Research Blog • 🤖 Gemini × Robotic Arms • 📚 Publications (21 Papers & 14+ Patents) • 📱 Free Live Apps • 🎓 Tutorials ↗
Claimed 1st Place at the prestigious Google Gemini 3 Seoul Hackathon 2026, standing out among 111 finalist projects and over 1,500 highly competitive applicants.
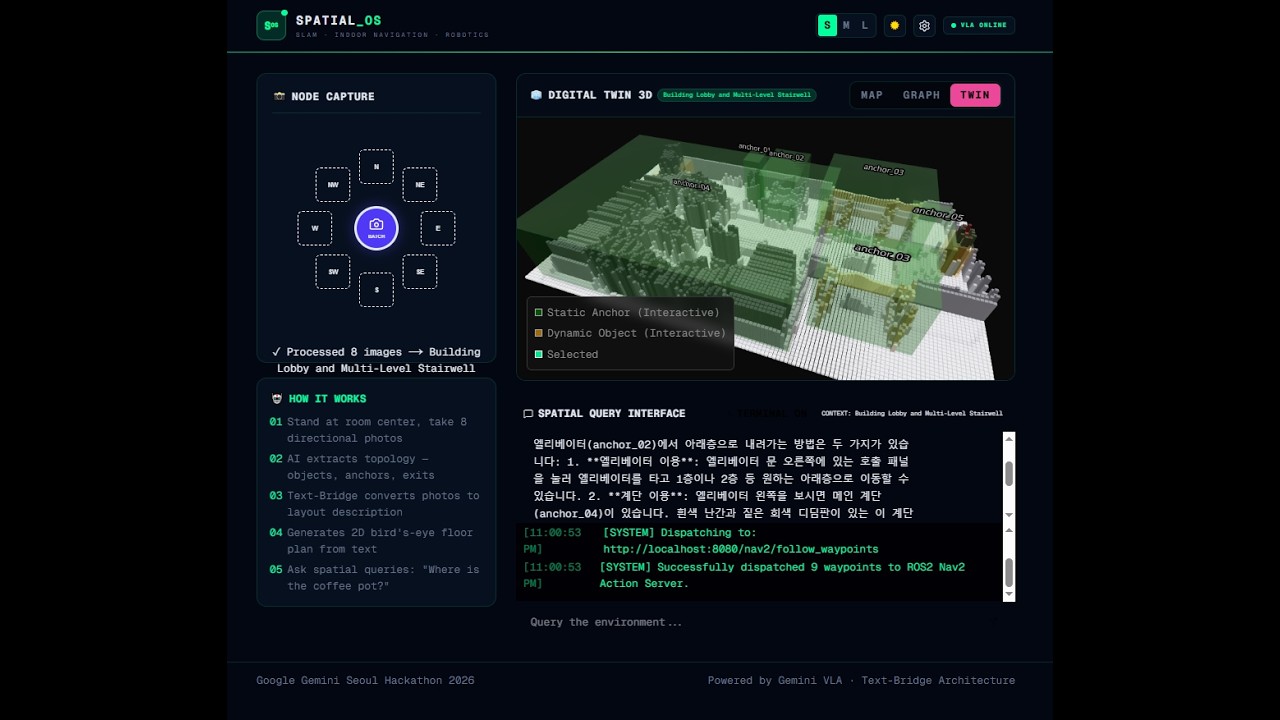
About GeminiSpace:
We developed GeminiSpace, a Vision-Language-Action (VLA) navigation system that turns standard 360° indoor room photos into an interactive indoor semantic map. Simply capture your space and query it naturally, acting as a smart GPS for any indoor environment.


Explore all visual TL;DRs and 40-second gemini-omni-1.1-flash video syntheses at mincasurong.github.io/blog:
|
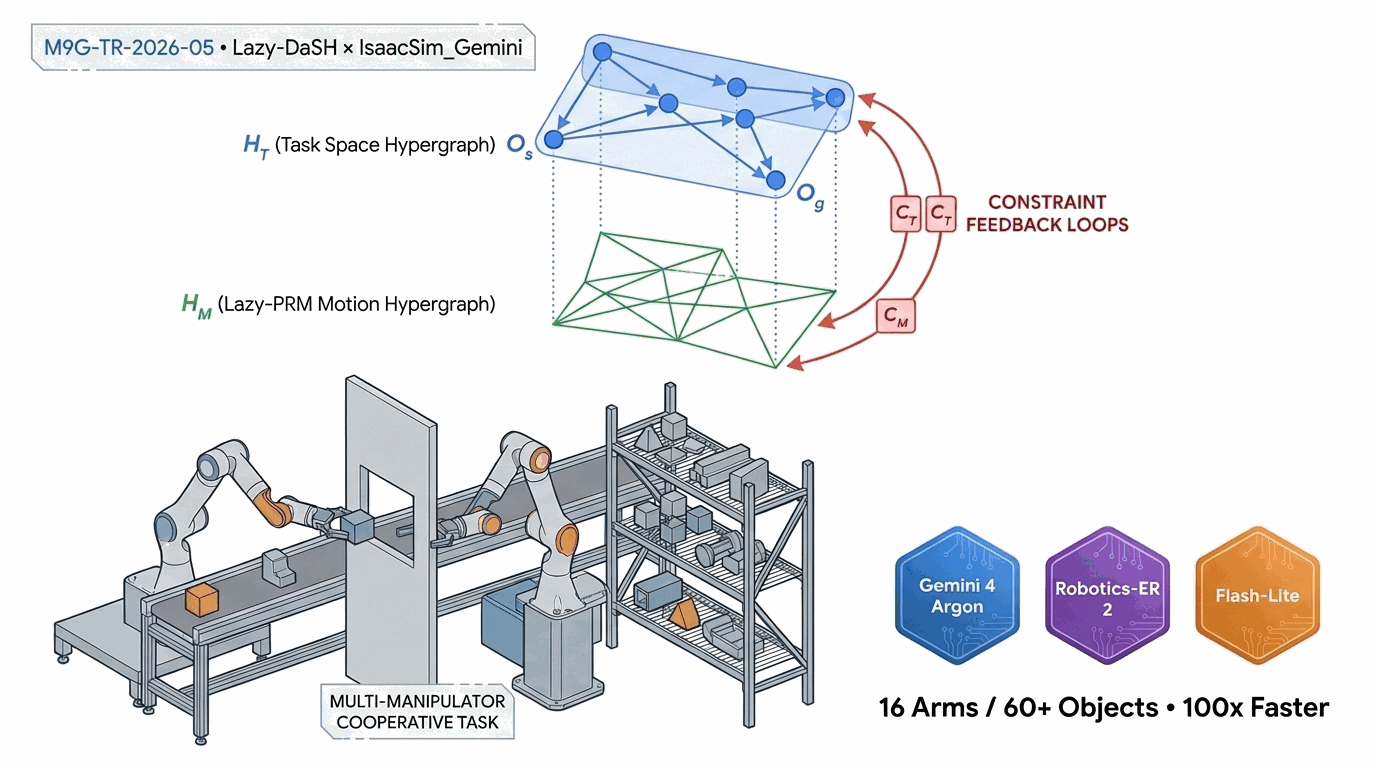
Summarizing Seongwon "Scott" Lee et al.'s Lazy-DaSH (UIUC Parasol Lab, arXiv:2504.05552) and mapping its 4-layer lazy hypergraph (H_T → H_M) & branch-scoped constraint feedback onto Gemini 4 Argon, Gemini Robotics-ER 2, and Gemini 3.5 Flash-Lite with 7 continuous KPIs. |

|
SOTA Survey (2025–2026): Agentic Multi-Robot Manipulation in NVIDIA Isaac Sim — Assembly, Deformables & Self-Driving Labs4-tier neuro-symbolic + GPU physics synthesis across MATTERIX, APEX-MR, RoboFactory, DexGarmentLab, ORGANA, and Project STAMP (v1.0.0-stamp). |

|
4-stage closed-loop Spatial, Task & Motion Planning (Plan → Gate → Execute → Write-Back) intercepting 610/610 kinematic, AABB collision, torque, and zone-lock faults in Isaac Sim 6.0 & ROS 2 Jazzy. |

|
Source-level post-mortem of engineering a 28-module coding harness, its 6 standalone failure modes, and extracting its 7 deterministic tools into the |

|
3-Stage hardware-in-the-loop benchmark in Isaac Sim 6.0 & ROS 2 Jazzy achieving a 10-turn pipelined schedule with 0 RGB tokens and -76.6% API cost ($0.01972). |
Multi-Robot VLA Manipulation, React Flow Digital Twins & Hardware-in-the-Loop Benchmarks (mincasurong/IsaacSim_GeminiRobotics).
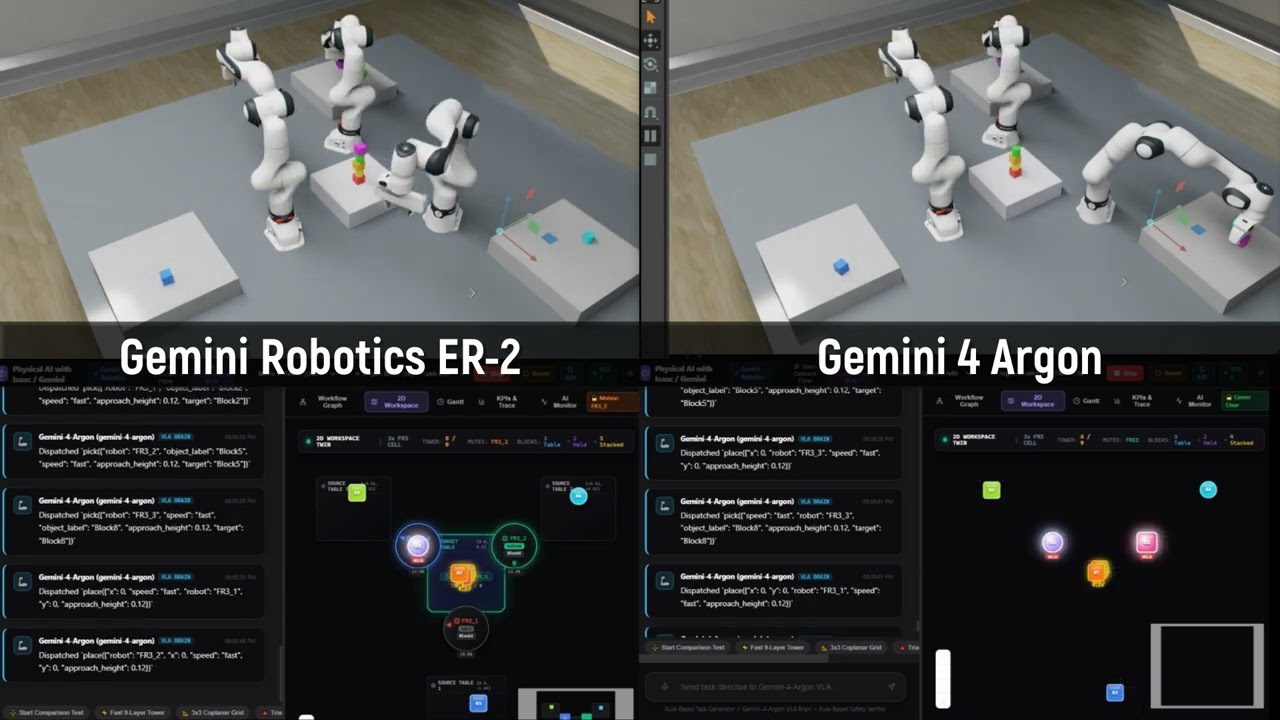
Side-by-side 3-arm 9-block tower benchmark in Isaac Sim 6.0: software-pipelined 10-turn scheduling and hybrid Gemini 4 Argon + Flash-Lite cutting API cost by 76.6% ($0.01972) with 0 RGB tokens. |
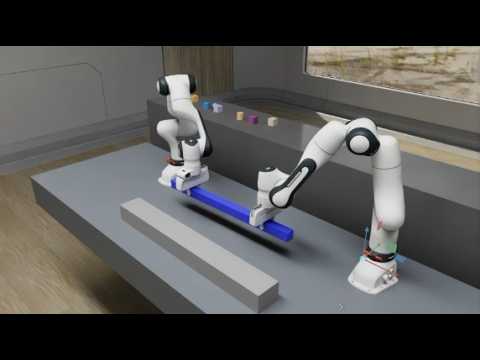
Three FR3 robotic arms cooperatively constructing geometric formations in Isaac Sim with dual zero-token React Flow DAG and Gemini Robotics-ER 2 VLA execution. |
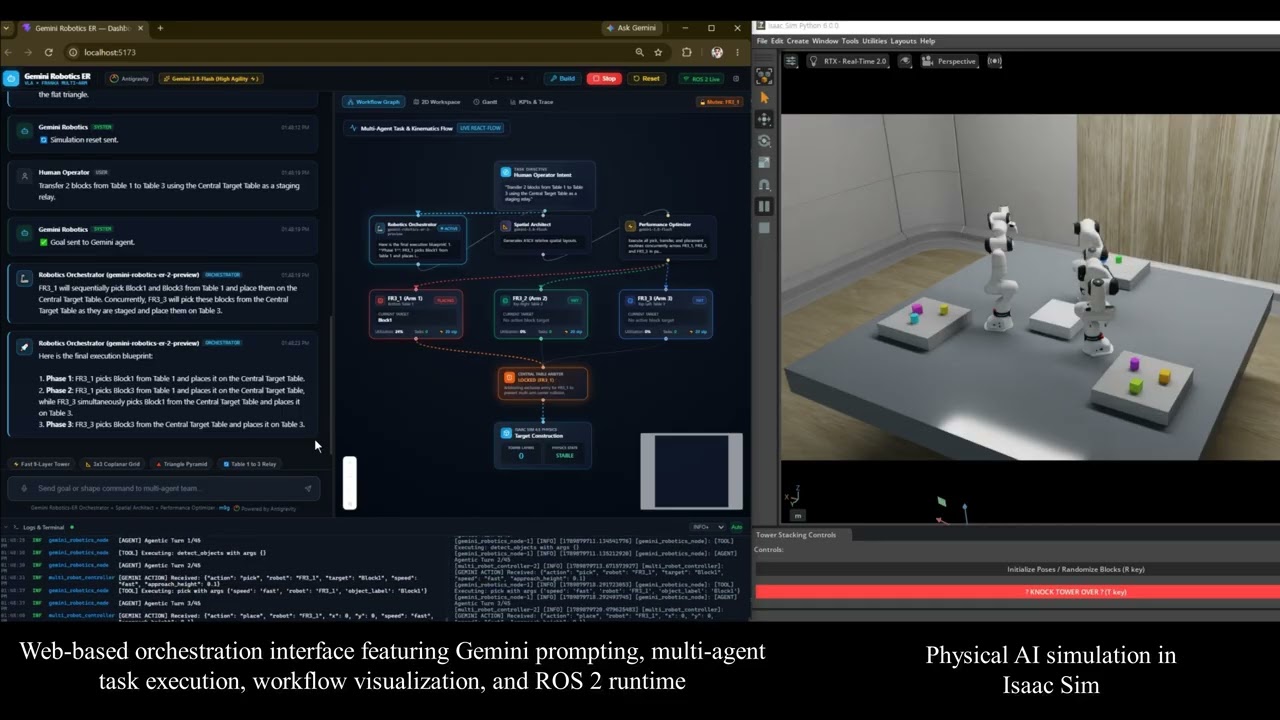
Cooperative FR3 robotic arms planning and assembling in NVIDIA Isaac Sim via Gemini multi-agent reasoning and React Flow digital twin. |
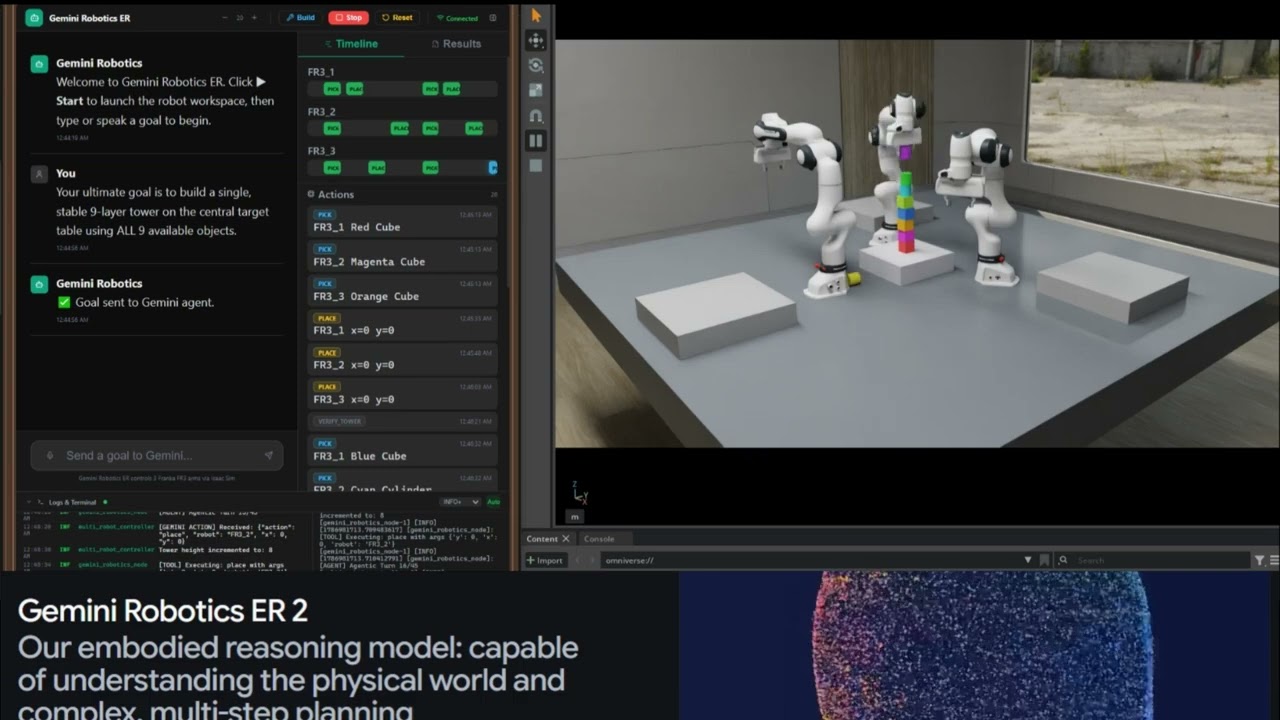
End-to-end VLA multi-robot control framework integrating Gemini Robotics-ER 2, Isaac Sim, ROS 2, and real-time Web monitoring GUI. |
Full list of 21 Peer-Reviewed Publications and 14+ US/KR Patents is available at mincasurong.github.io/archive and mincasurong.github.io/vcard.
| Year | Venue | Paper Title | Link |
|---|---|---|---|
| 2026 | IEEE/RSJ IROS | SPLiT: Spatially Generalizable Phase-Partitioned Motion Generation for Adaptive Liquid Transfer (H. Kim, S. Jeon, M. Chang, H. Lee, J. Park) | Google Scholar ↗ |
| 2025 | IEEE ICRA | OPPA: Online Planner's Parameter Adaptation for Enhanced Mobile Robot Navigation | IEEE Xplore ↗ |
| 2020 | IEEE TNSRE | AI Therapist realizing Expert Verbal Cues for Effective Robot-Assisted Gait Training | IEEE Xplore ↗ |
| 2019 | IEEE TNSRE | Research on Terrain Identification of the Smart Prosthetic Ankle by Fuzzy Logic | IEEE Xplore ↗ |
| 2019 | Applied Sciences | Precise flowrate control of fluid gear pump in automated painting system using a repetitive controller | MDPI ↗ |
| 2017 | ICORR / Rehabweek | A research on the postural stability of a person wearing the lower limb exoskeletal robot by the HAT model | IEEE Xplore ↗ |
🦿 Virtual Reality (VR) + Wearable Robots for Rehabilitation (Click to expand/collapse)
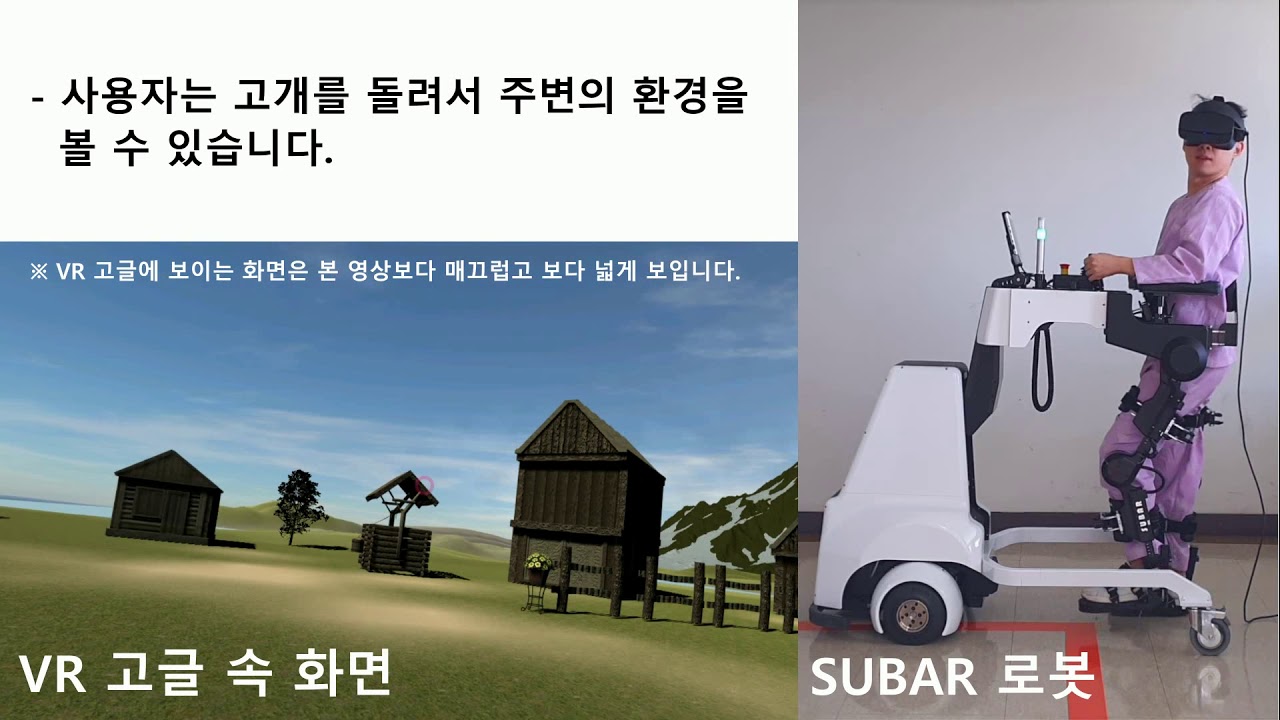
VR-Integrated Lower Limb Exoskeleton Interactive VR environment with synchronized biofeedback for gait rehabilitation. |
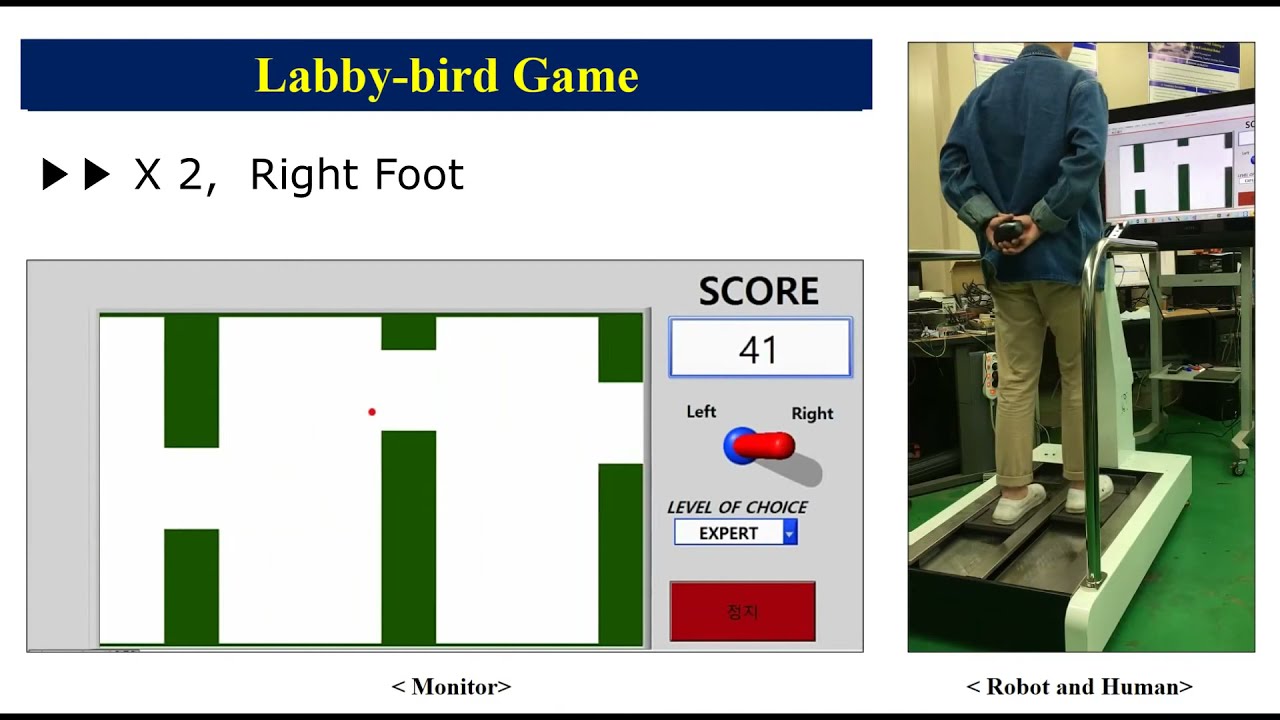
Adaptive Impedance Control Exoskeleton Gamified assist-as-needed gait training using adaptive impedance control. |

Virtual Spring-Damper Gait Guidance Trajectory constraint control along predefined paths for robotic gait assistance. |
🚙 Mobile Robots, Navigation & Manipulators (Click to expand/collapse)
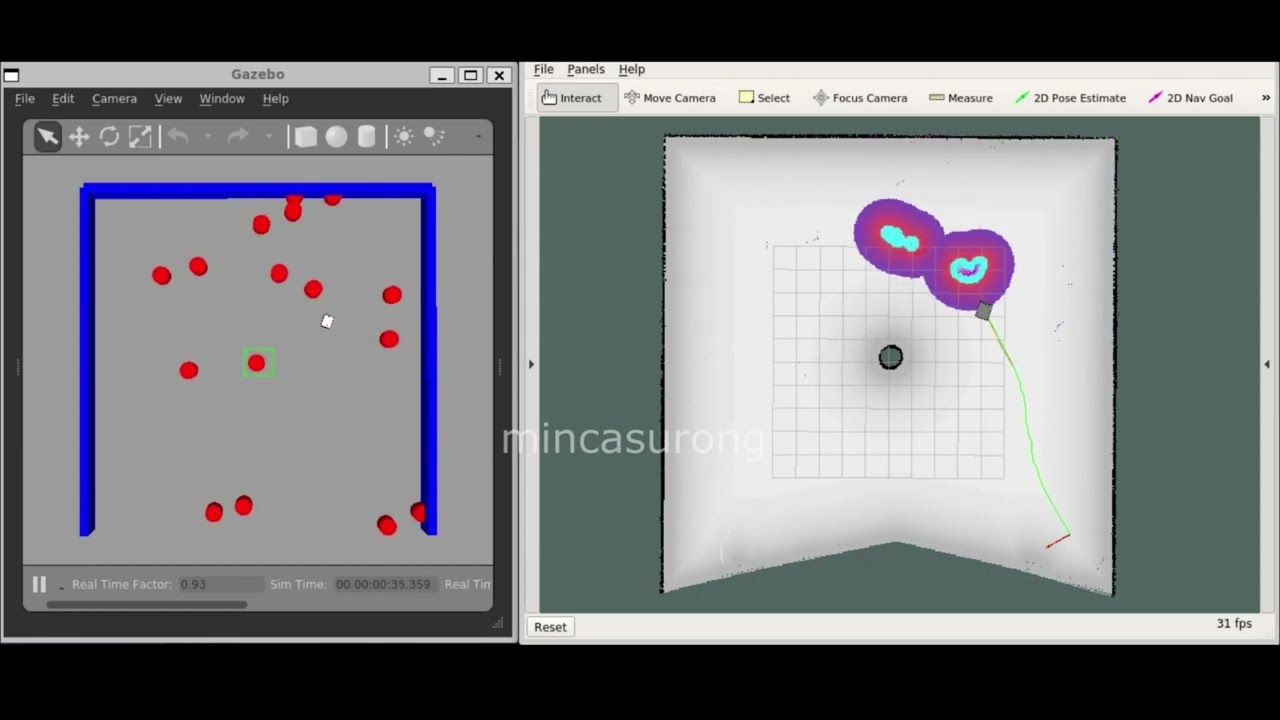
BARN Benchmark Path Planning Autonomous mobile navigation and dynamic obstacle avoidance benchmarking. |

ROS 2 & MoveIt 2 Motion Planning Collision-free robotic arm trajectory planning running natively on Windows 10. |

Jetson Nano ROS Autopilot Edge AI autopilot and sensor-driven motion control on Jetbot platform. |

Master Chinese characters and Japanese vocabulary in 3 minutes a day on Google Play. |

Real-time conversational AI voice sparring trainer for OPIc Advanced Low (AL). |

Full-section Japanese proficiency exam simulator with 1:1 Gemini AI weak-spot tutoring. |
| Domain | Technologies |
|---|---|
| Robotics & Simulation | NVIDIA Isaac Sim 6.0 ROS 2 Jazzy MoveIt 2 MuJoCo 3.x Franka Emika FR3 Jetson Nano |
| AI & Spatial Intelligence | Gemini 4 Argon Gemini Robotics-ER 2 Gemini 3.8 / 3.5 Flash-Lite Visual SLAM VLA & TAMP |
| Full-Stack & Digital Twins | React 19 TypeScript 5.8 React Flow v12 Vite 6 Tailwind CSS v4 FastDDS Unicast |
| Cloud & Agentic DevOps | Google Cloud Run Model Context Protocol (MCP) Docker GitHub Actions PyTorch |
The M9G Formula: m incasuron g (Human Engineering) × m insu chan g (Agent-enabled Intelligence)


© 2026 M9G (Minsu Chang, Ph.D.) • Built in Public • mincasurong.github.io